
Real roads. Real-time inference.
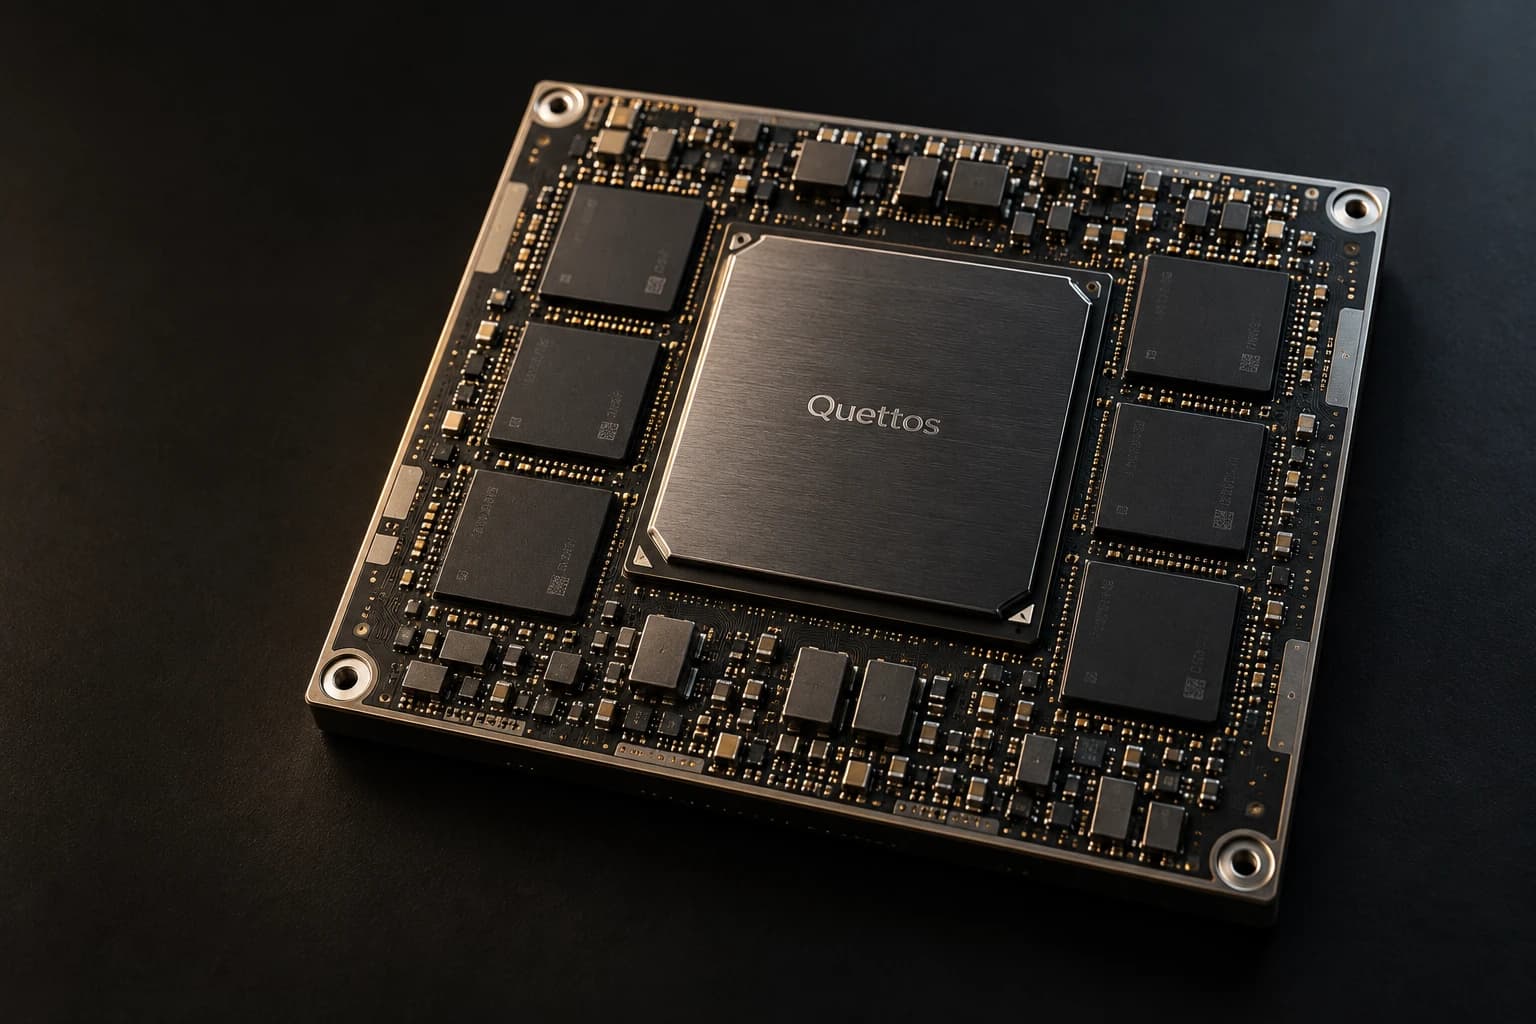
A left-turn collision warning system for novice drivers. Our team built a vehicle-mounted system that detects oncoming traffic and assesses threats, with quantized YOLO11 running entirely on a Jetson Orin Nano.
MY ROLE / EMBEDDED INFERENCE
Read the build story I built and optimized the embedded inference pipeline: compiling OpenCV with CUDA, converting the model with TensorRT, and tuning live video processing end to end.